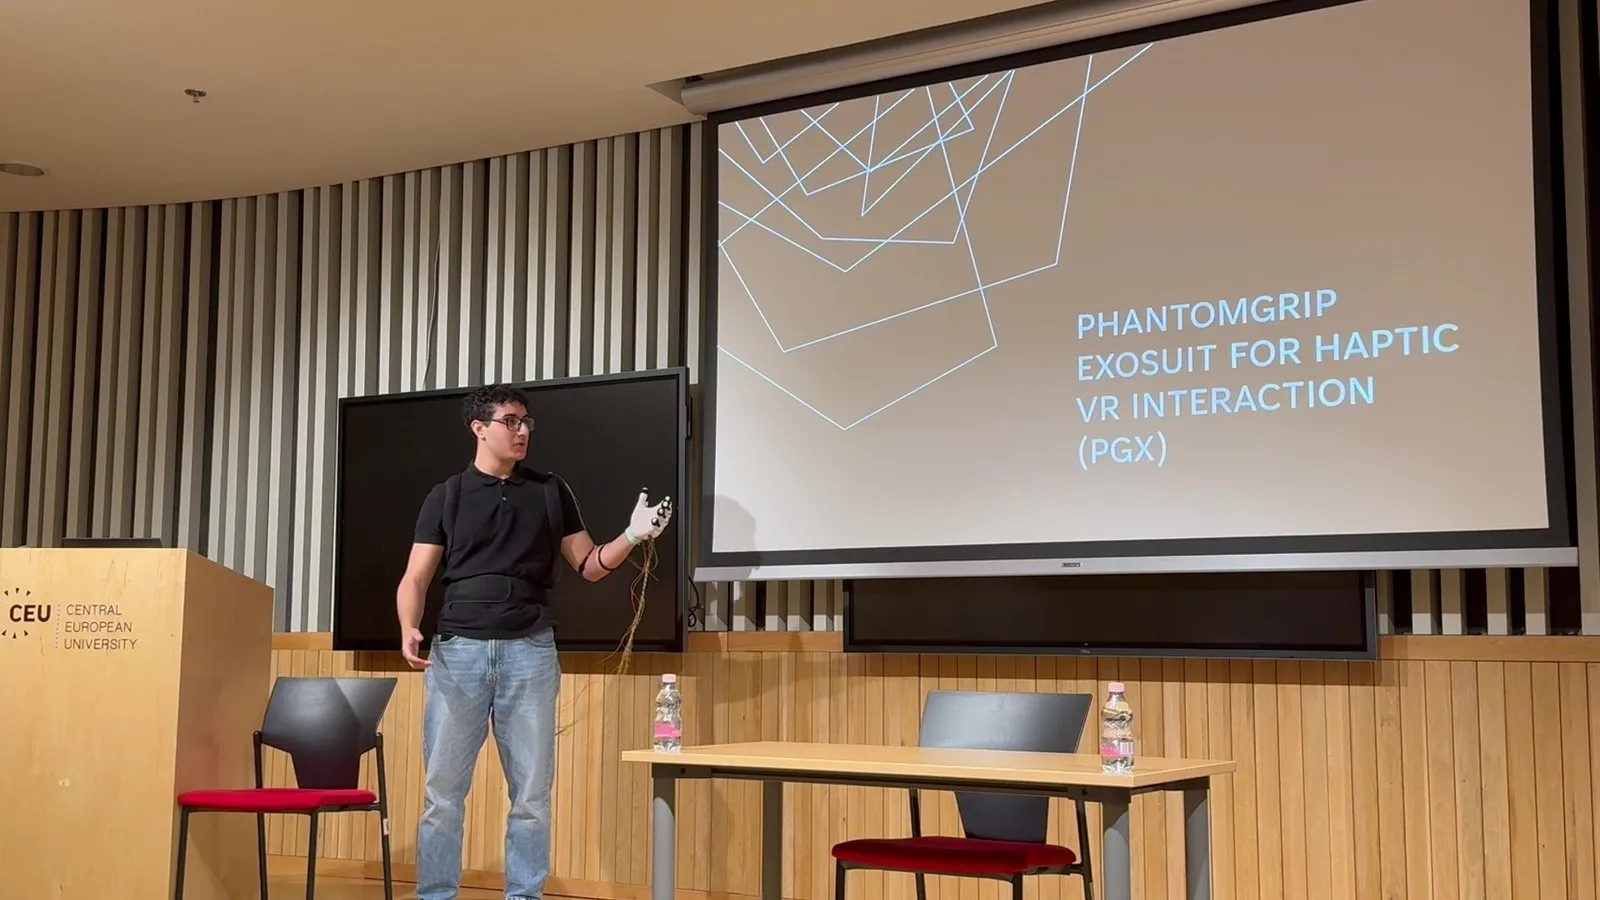
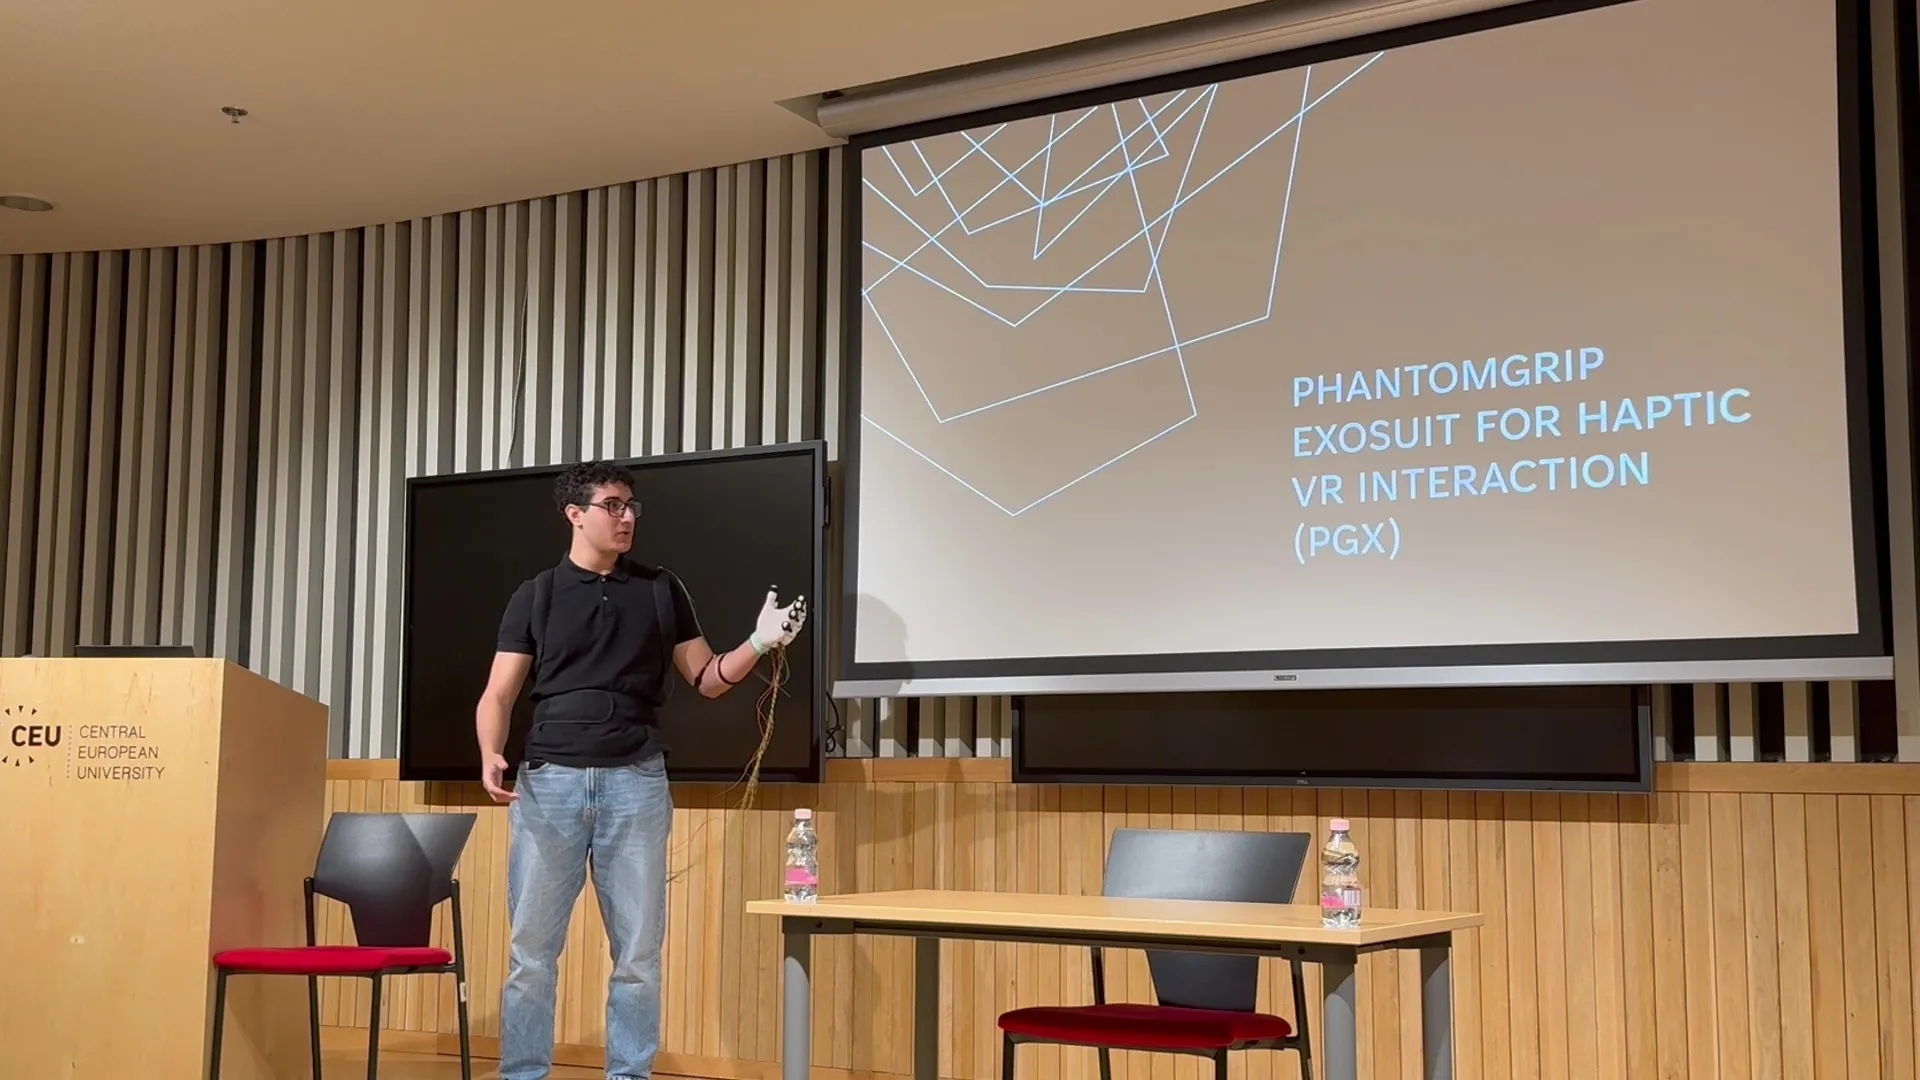
PGX, PhantomGrip eXosuit
A cable-driven VR exosuit. Grab a virtual object and your fingers stop where its surface is.
Role Solo project
Force feedback for VR that physically resists your fingers. Motors on a back brace pull steel cables routed to each finger, and Unity drives them from Quest 3 hand tracking. Six months of mechanical design, firmware and XR work, presented publicly, then set aside.
The idea
If you grab an apple in VR, your fingers should stop where the apple is. That was the whole project: affordable, cable-driven force feedback for a full hand.
What I built
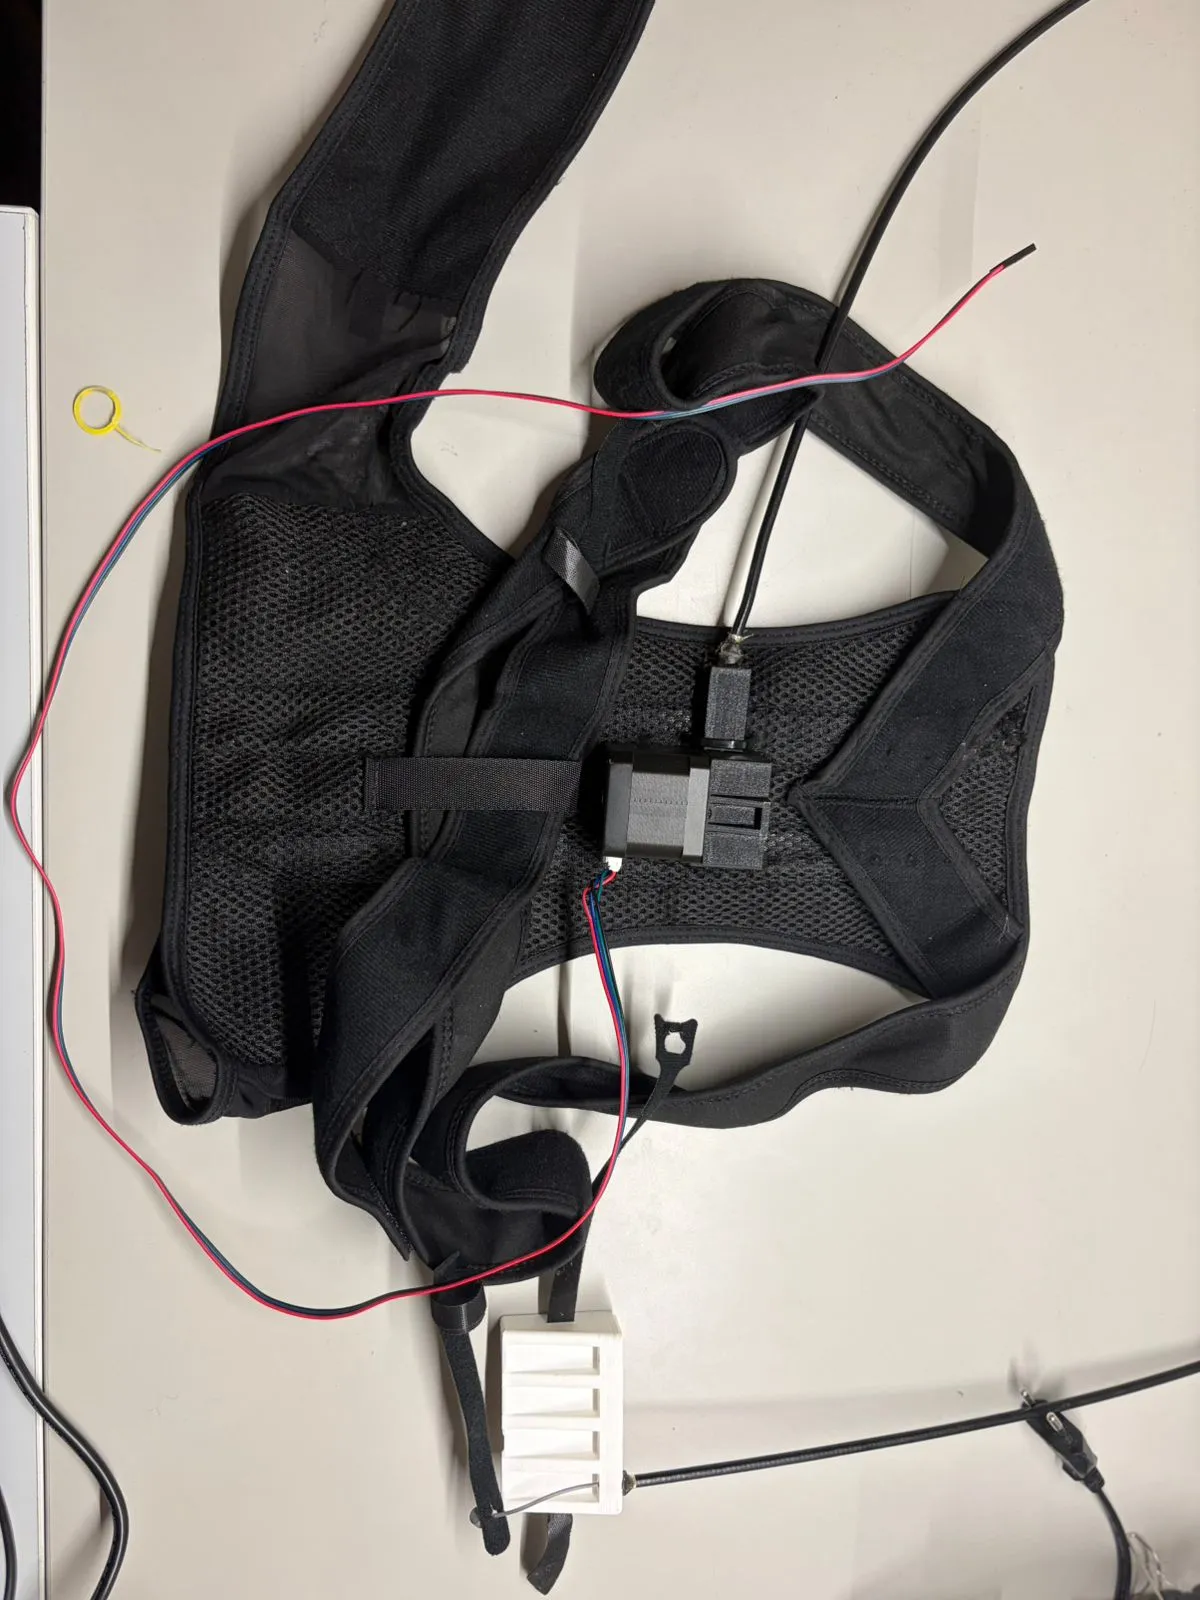
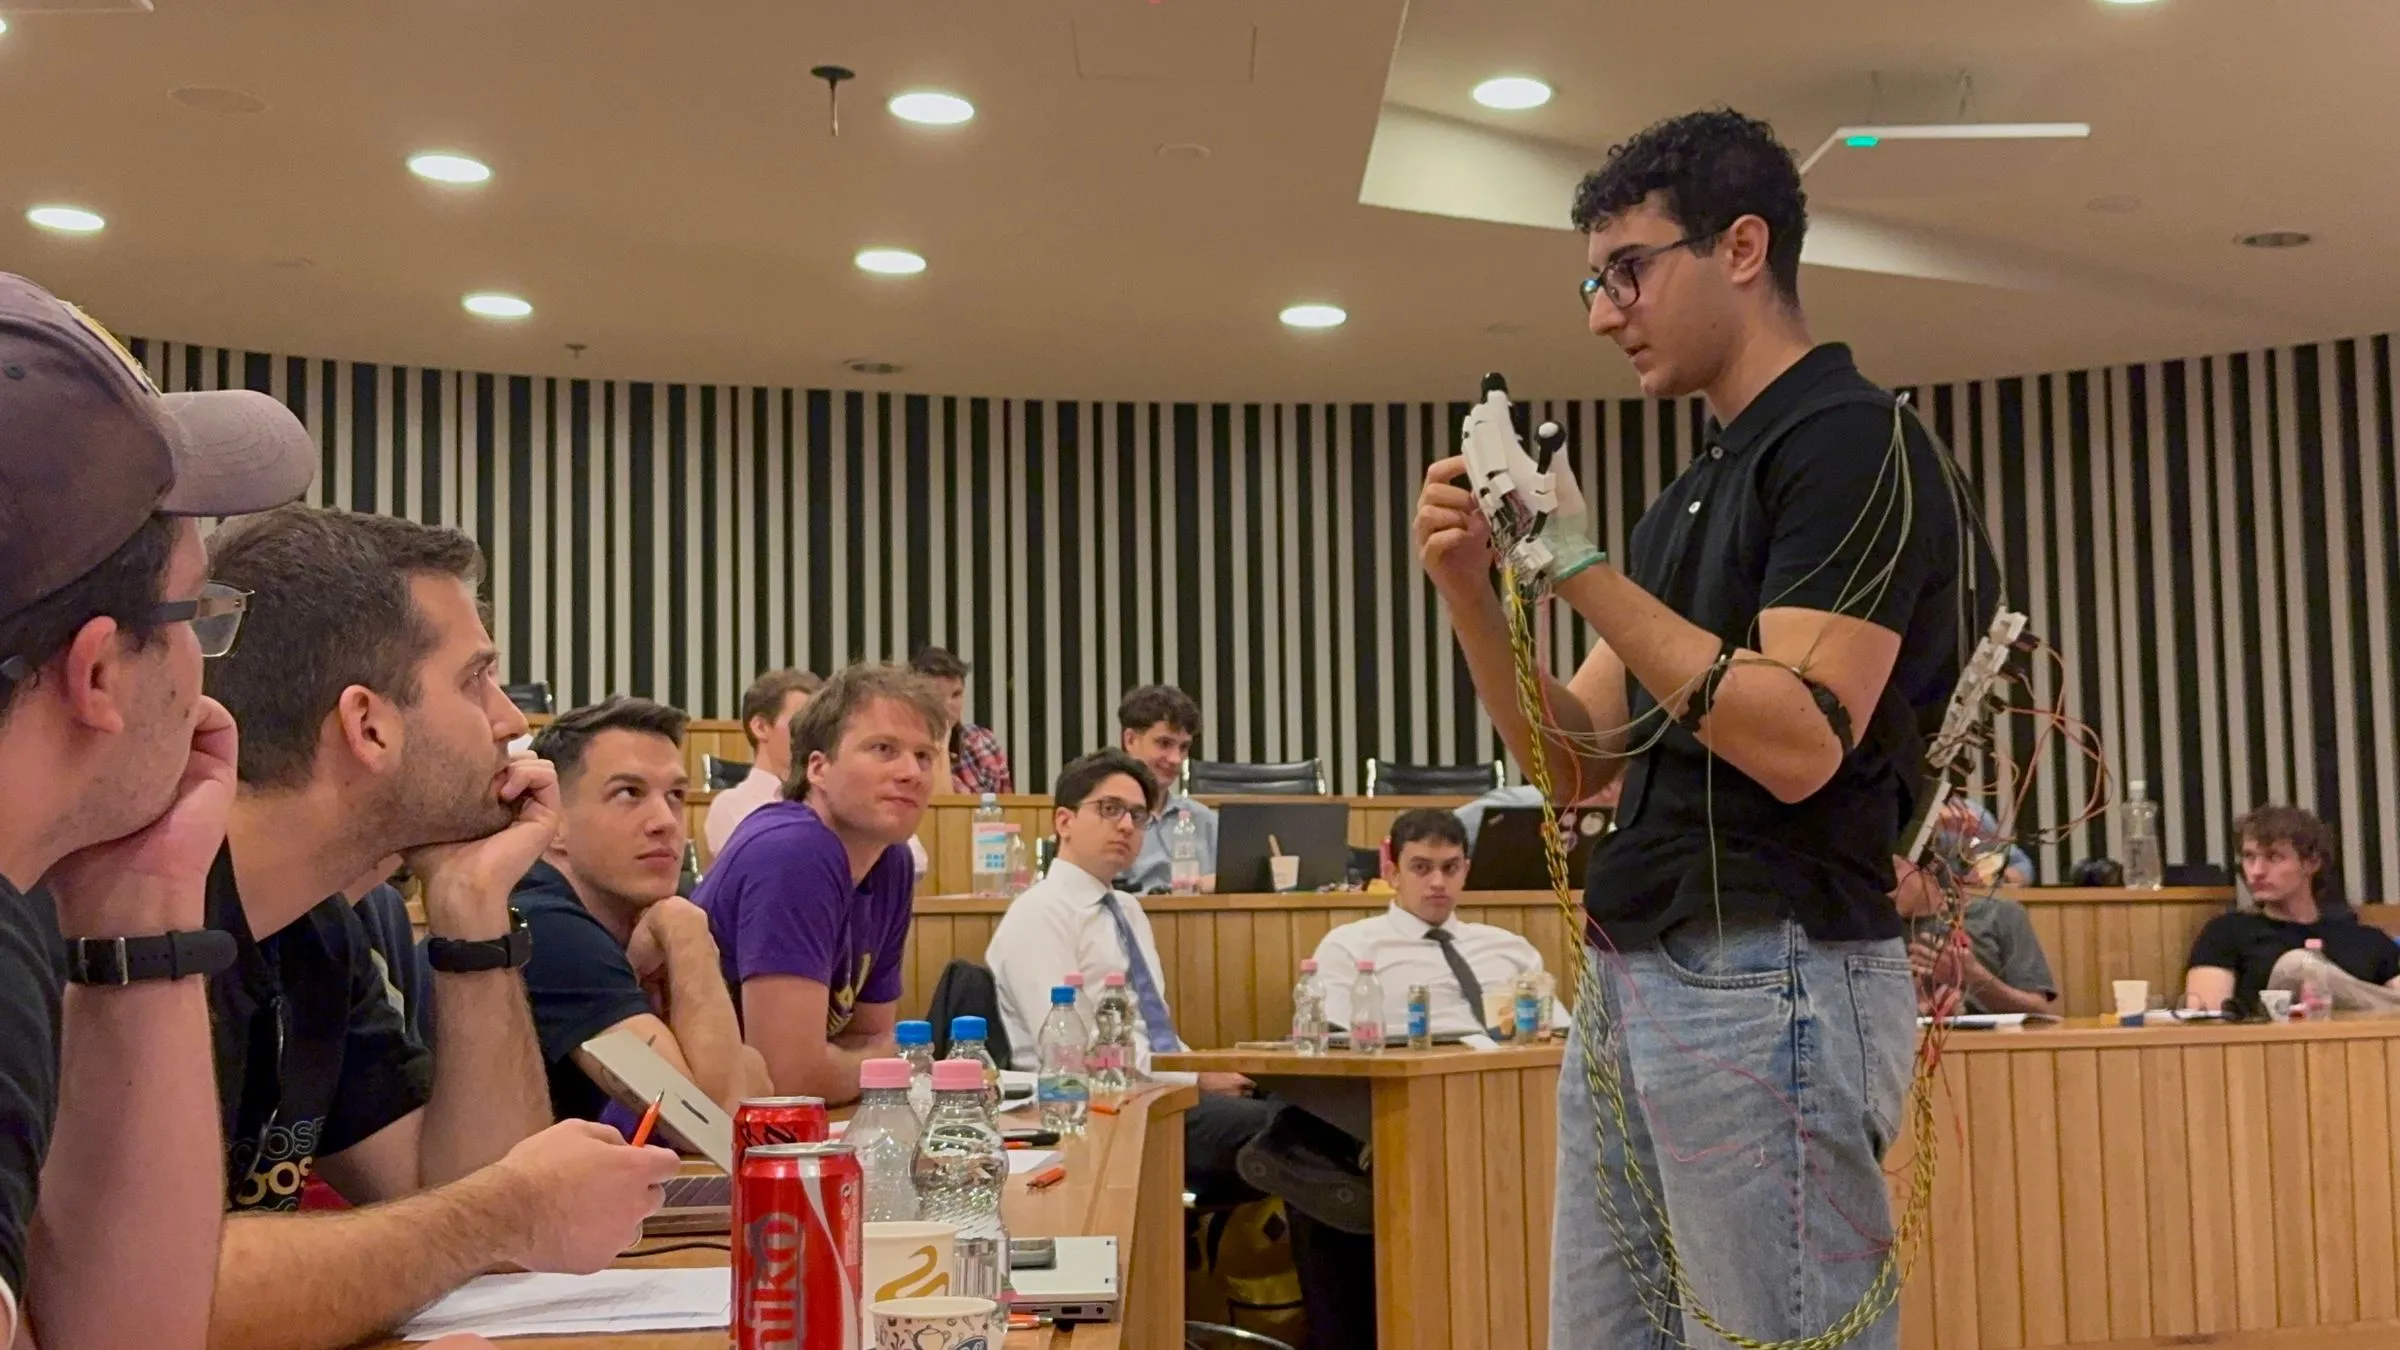
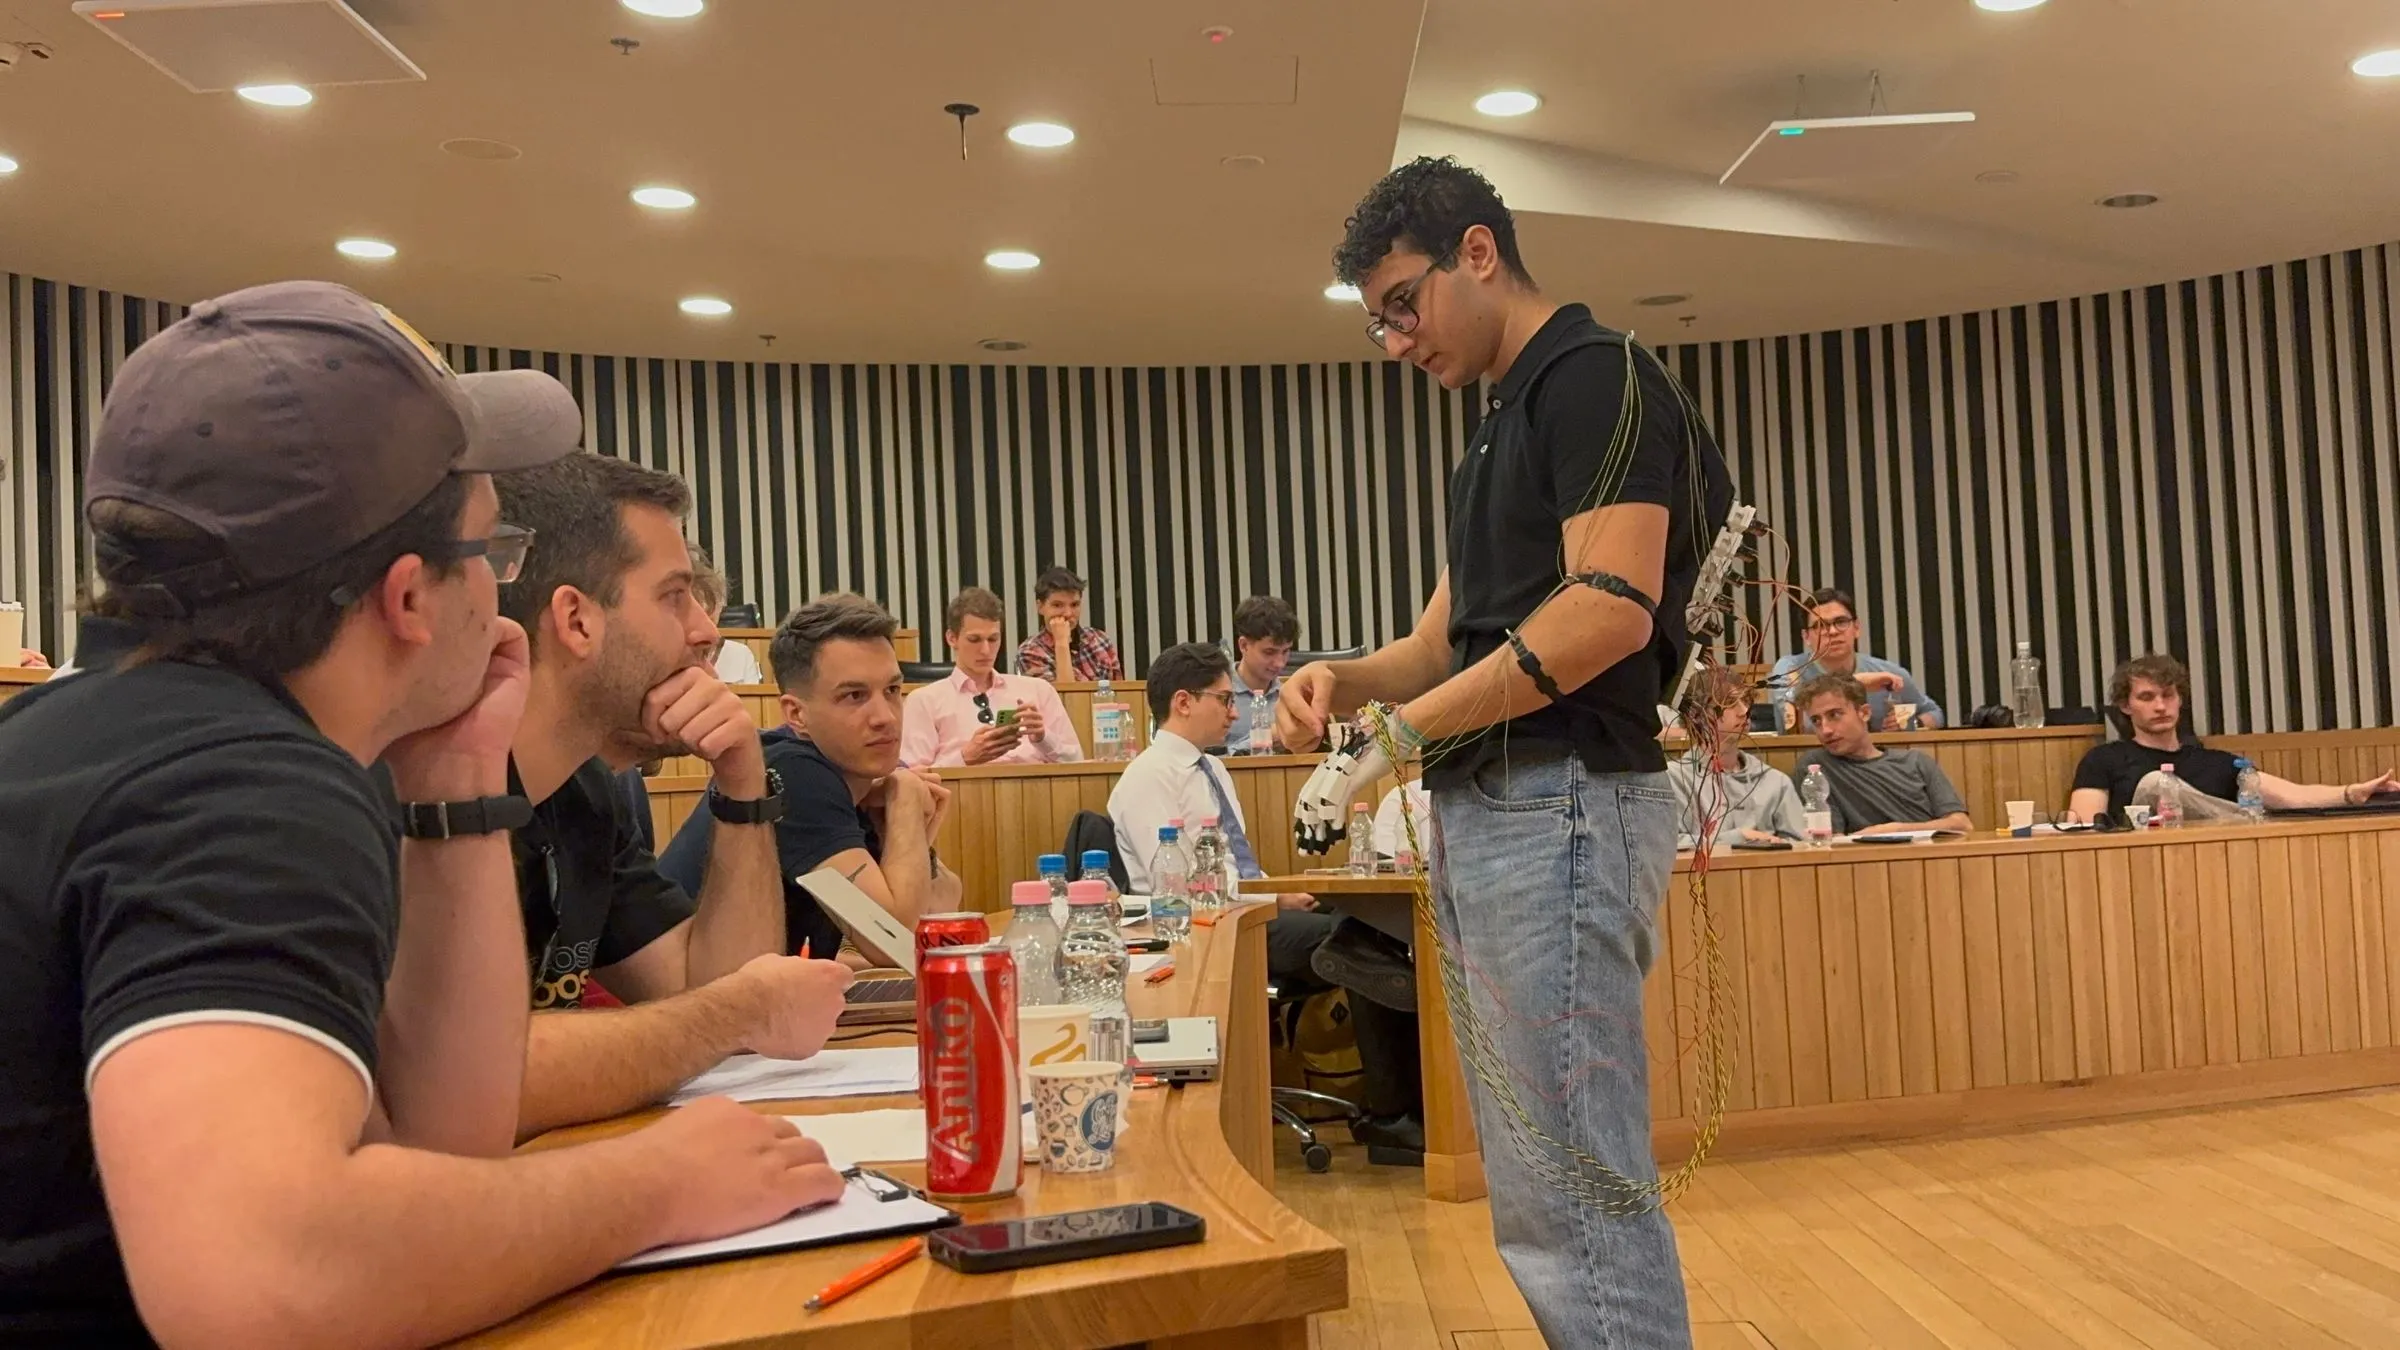
- A back brace carrying all five motors. Each spools a steel cable routed through printed pulleys to a finger strap. Servos first, then steppers, whose holding torque gives firmer and less spongy resistance.
- An input glove with a magnet and a hall-effect sensor on every finger joint, reading curl directly, plus a live visualiser to debug it.
- A Unity bridge streaming Quest 3 hand tracking to an ESP32, which turns finger curl into motor tension.
Putting every motor on the back is what made it wearable. The hand carries nothing but the strings that pull it.
Why it stopped
Building for the human body is brutal. Every hand is different, velcro shifts, cables snag, and a rig that works on the desk fails on your arm. After six months I archived it. It had taught me what it was going to teach me, and it pointed straight at the simpler idea that became OpenResonance.
Signal path
06 stages- 01 Quest 3 hand tracking
- 02 Unity is the hand inside an object?
- 03 ESP32 curl to tension
- 04 Stepper on the back brace
- 05 Steel cable through printed pulleys
- 06 Your finger stops moving
Every motor lives on the back brace, so the part strapped to your hand carries nothing but the cables that pull it.
On video
01 clipsMore
05 photos